Electromagnetics电磁
The laboratory studies intelligent electromagnetic sensing and magnetic tactile perception, including inspection, sensing, and arrayed multidimensional force estimation, to support robot contact sensing and measurement in advanced mechatronic systems.
面向智能电磁感知与磁触觉,实验室开展检测、传感与阵列化多维力感知研究,为机器人接触感知和先进机电系统测量提供技术支撑。
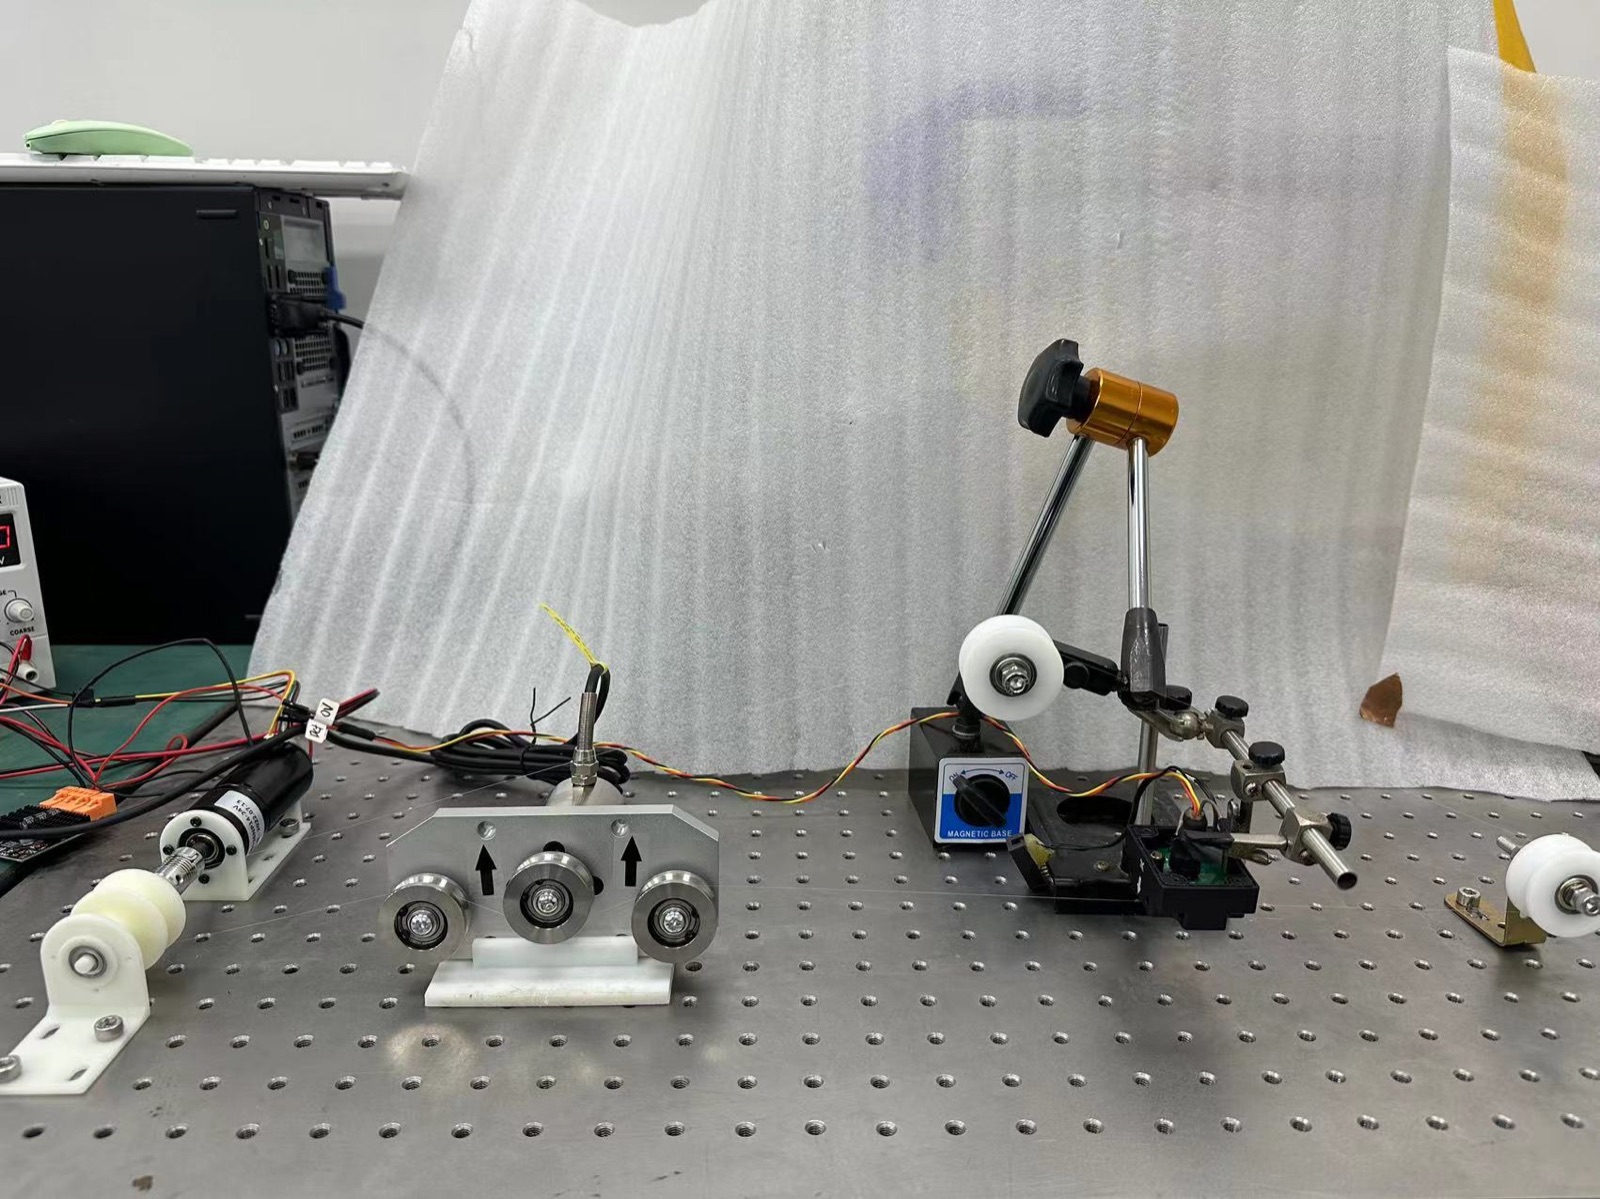
Arrayed Multidimensional Magnetic Tactile Sensing阵列化多维磁触觉感知
To meet the need for high-precision tactile sensing in robots, we study arrayed magnetic tactile methods for dexterous hands, biomimetic fingertips, and contact on complex surfaces. The approach combines magnetic sources and Hall-sensor arrays to estimate multidimensional force. By jointly optimizing crossed-polarity magnets, triaxial Hall arrays, and compliant elastic structures, we capture contact-induced field changes with high sensitivity and map those responses to force through physical modeling and decoupling. We currently obtain stable six-axis wrench estimates and further recover the three-dimensional force distribution over the contact patch, providing contact location, magnitude, and direction.
For curved fingertips and multi-point contact, we further study multi-module array layout, surface reconstruction, curved-surface mapping, and multi-region fusion, moving from discrete sensing units toward a continuous tactile surface. Physics priors, structural constraints, and neural calibration compensate for nonlinearity, axis coupling, unit-to-unit variation, and manufacturing error. Ongoing work includes multi-point calibration, surface densification, contact-patch reconstruction, and multimodal tactile fusion. These results can supply high-resolution, multidimensional tactile information for dexterous grasping, contact-state recognition, slip detection, fine manipulation, and embodied interaction, with potential in biomimetic robots, intelligent manufacturing, and human–robot collaboration.
实验室围绕机器人高精度触觉感知需求开展阵列化磁感触技术研究,面向灵巧手、仿生指尖和复杂曲面接触等应用场景,构建了基于磁源—霍尔阵列协同设计的多维力感知方案。团队通过交叉极性磁源、三轴霍尔传感阵列及柔性弹性结构的协同优化,实现接触过程中磁场变化的高灵敏采集,并建立了由磁场响应到多维力信息的物理建模与解耦方法。目前已实现整体六维力的稳定解算,并进一步由整体力与力矩信息反演阵列化接触区域内的三维力分布,为机器人获取接触位置、受力大小和受力方向等信息提供了重要技术支撑。
围绕曲面指尖和多点接触感知需求,实验室进一步开展多模组阵列布局、感触面重构、曲面映射与多区域融合研究,逐步形成由离散感触单元向连续触觉表面的感知与可视化方法。团队结合物理先验、结构约束和神经网络标定,对传感器非线性、轴间耦合、个体差异及制造误差进行补偿,并持续推进多点标定、曲面增密、接触斑重构及多模态触觉融合等关键技术。相关成果可为灵巧抓取、接触状态识别、滑移检测、精细操作及具身智能交互提供高分辨率、多维度的触觉信息,具备在仿生机器人、智能制造和人机协作等领域的应用潜力。