 Huazhong University of Science and Technology华中科技大学
School of Mechanical Science and Engineering机械科学与工程学院
Mechatronicsand control 智能机电与控制实验室
We build intelligent robots and advanced mechatronic systems that perceive, understand, and act — from emotionally expressive humanoids to dexterous hands and wearable exoskeletons.我们研究能够感知、理解与行动的智能机器人与先进机电系统——从富有情感的仿人机器人,到灵巧手与可穿戴外骨骼。
Robots that work with people让机器人更懂人、更好地协作
The Intelligent Mechatronics and Control Research Laboratory (IMCRL) is part of the Advanced Electronic Manufacturing Center in the School of Mechanical Science and Engineering at Huazhong University of Science and Technology. Led by Professor Min Li, the laboratory currently has more than twenty faculty members and students.
We address the needs of intelligent robots and advanced mechatronic systems through research on embodied human–robot interaction, dexterous manipulation, intelligent electromagnetic sensing, magnetic tactile perception, and wearable exoskeletons, with the goal of advancing both scientific innovation and industrial application.
智能机电与控制实验室(IMCRL)隶属于华中科技大学机械科学与工程学院先进电子制造研究中心,由李敏教授领衔,现有师生二十余人。
实验室面向智能机器人与先进机电系统的发展需求,围绕具身智能人机交互、灵巧操作、智能电磁感知、磁触觉和可穿戴外骨骼等方向开展前沿研究,致力于推动智能机电技术的创新发展与产业应用。
Research研究
Four connected directions spanning perception, control, and physical interaction.四个相互关联的方向,覆盖感知、控制与物理交互。
An integrated perception–cognition–generation–execution framework for natural, affective human–robot communication. 构建覆盖感知、认知、生成与执行的一体化交互框架,实现自然、富有情感的人机交流。
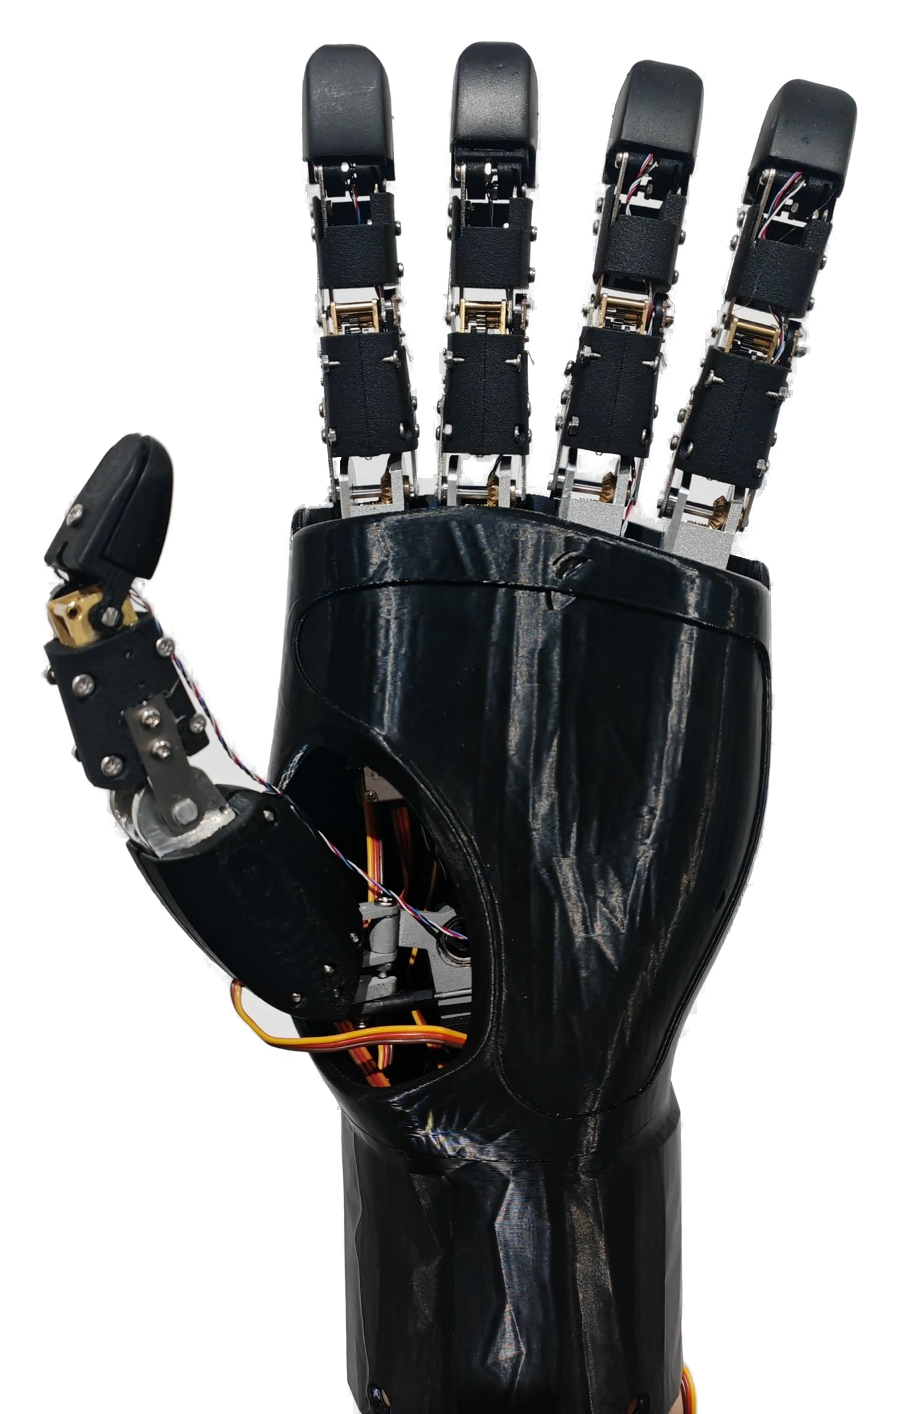
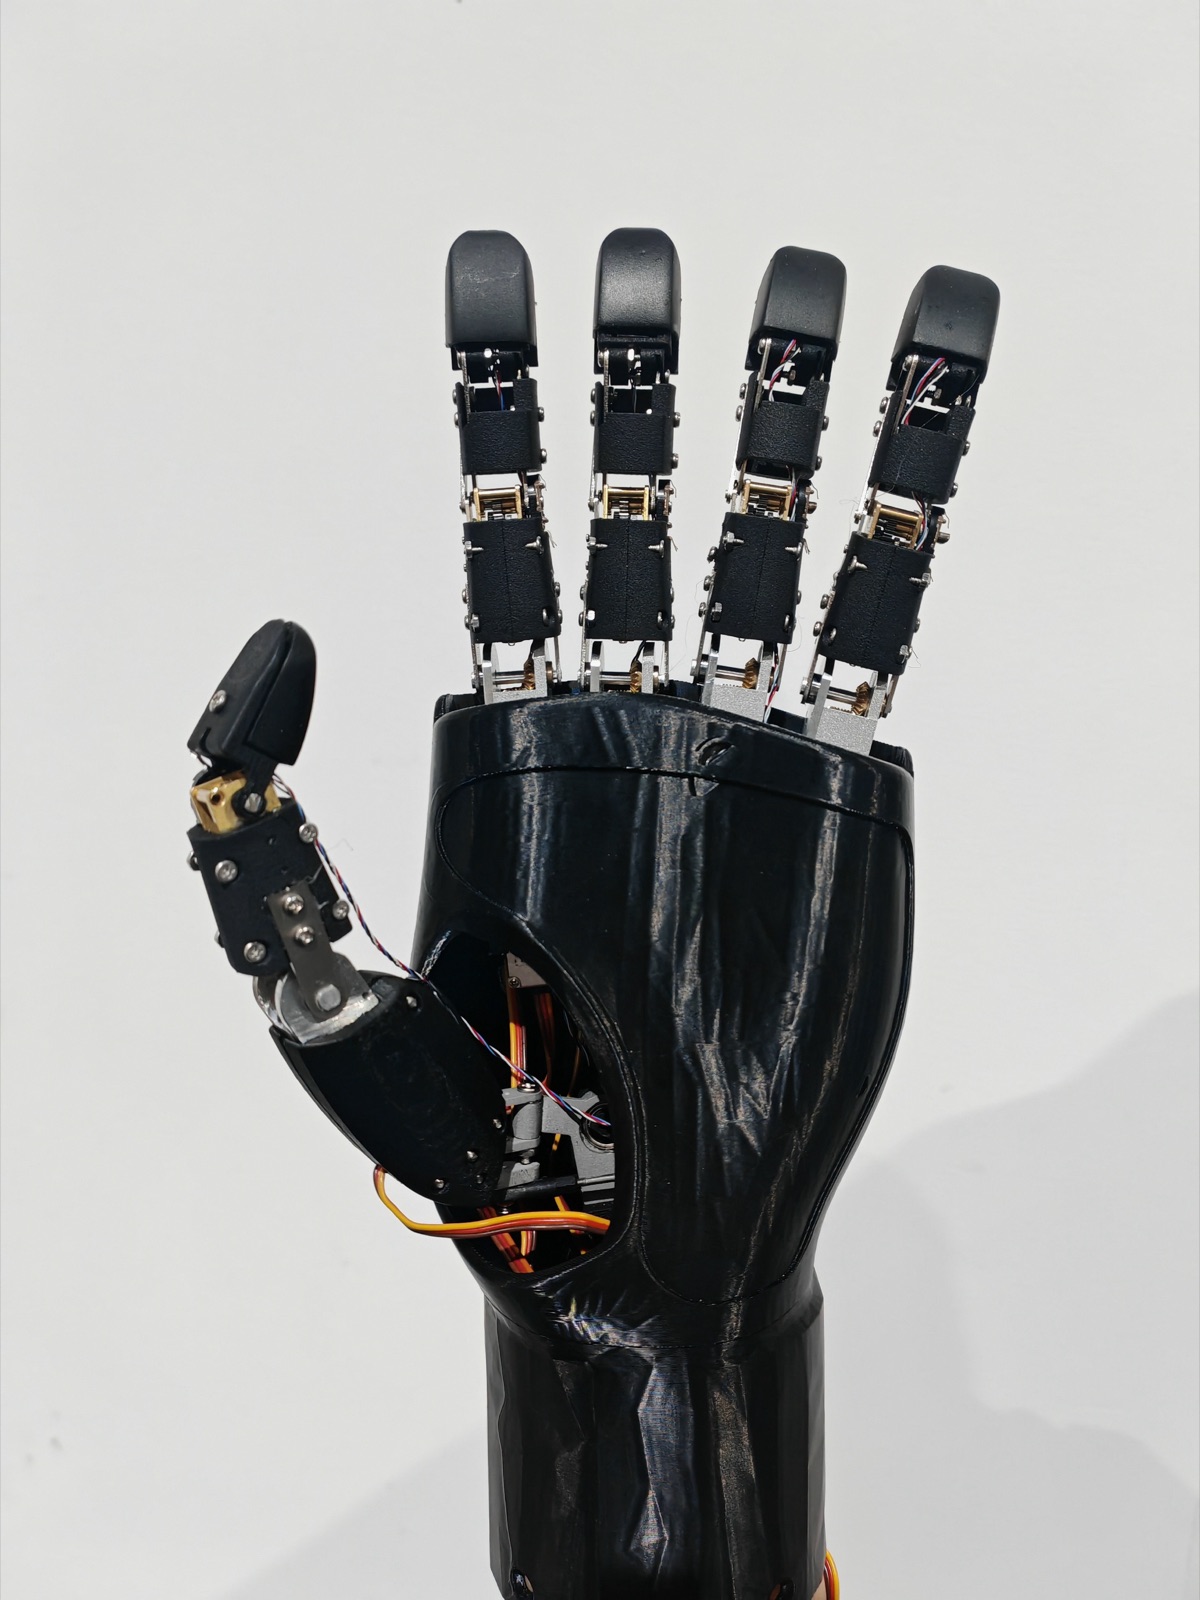
Dexterous hands, multimodal sensing, and visuo-tactile models for fine grasping and contact-rich tasks. 推进灵巧手、多模态感知与力触融合模型,服务精细抓取与富接触作业。
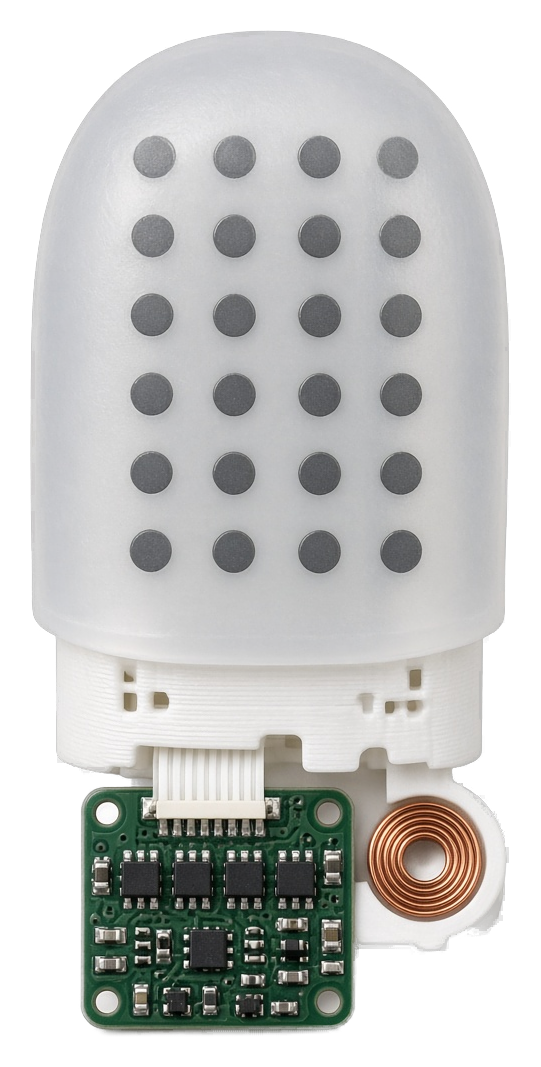
Electromagnetic inspection and arrayed magnetic tactile sensing for contact force and industrial measurement. 面向检测、传感与阵列化多维力感知。
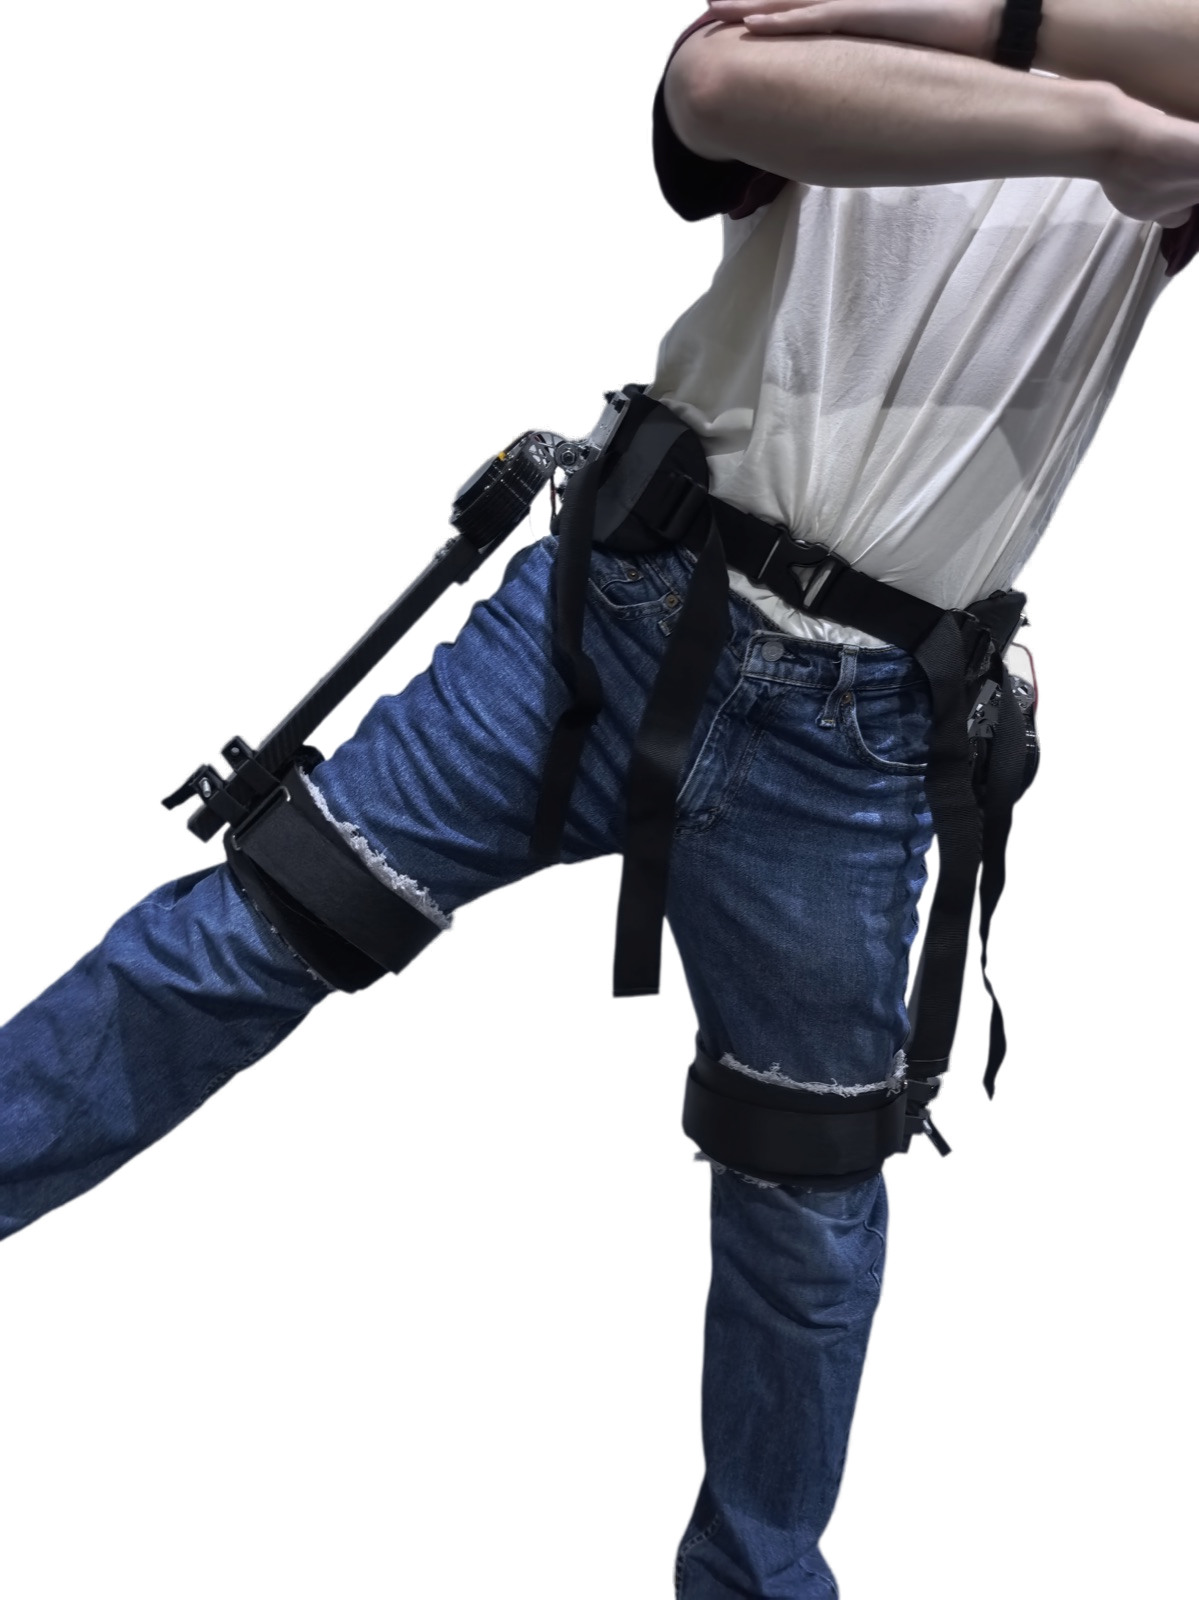
Lower-limb rehabilitation and walking assistance with lightweight, personalized exoskeleton systems. 围绕下肢人机共融康复与助行,形成轻量化、个性化助力方案。
News动态
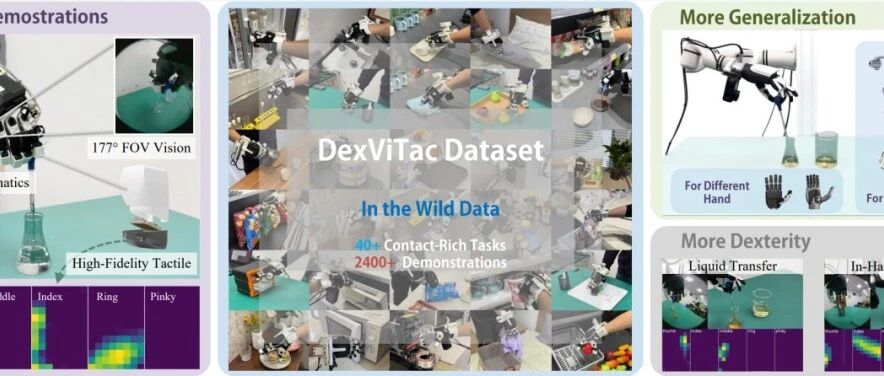
Our IROS 2026 paper presents DexViTac, a portable system and two-stage learning framework that turns natural human demonstrations with vision, touch, and hand kinematics into contact-rich robot skills.实验室 IROS 2026 论文提出 DexViTac,以便携式采集系统和两阶段学习框架,从人类自然示范中学习视觉—触觉—运动学融合的精细接触操作。
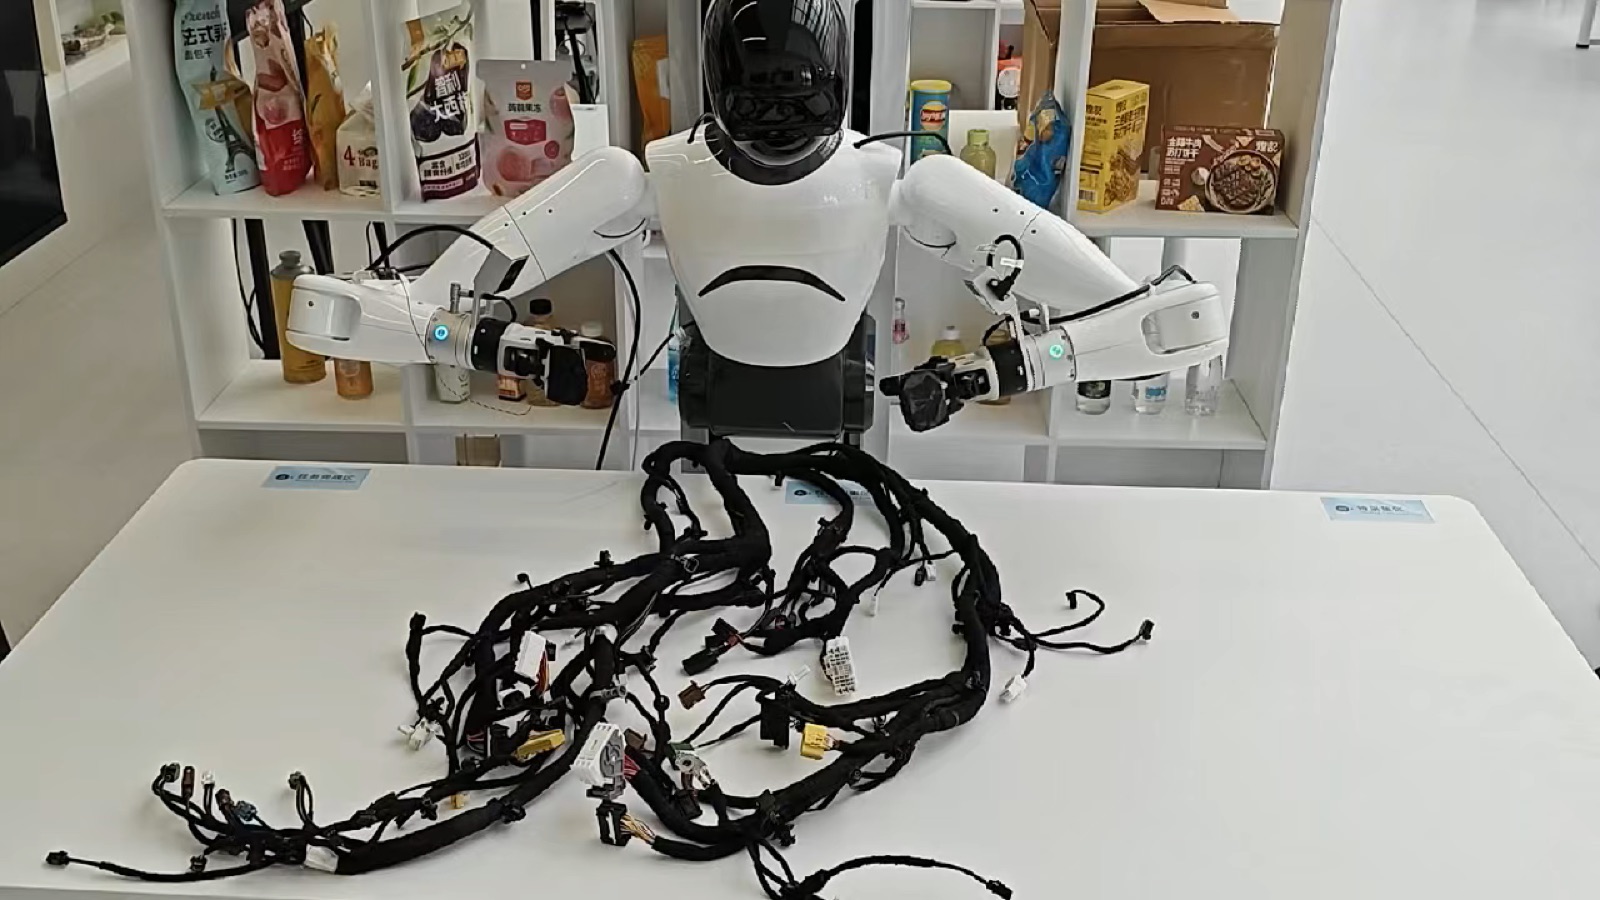
An overview of IMCRL's five research directions — embodied human–robot interaction, dexterous manipulation, wearable exoskeletons, intelligent electromagnetic sensing, and magnetic touch.实验室研究方向介绍:具身智能人机交互、灵巧操作、可穿戴外骨骼、智能电磁感知与磁触觉。
Meet the Team团队成员
Led by Professor Min Li, IMCRL brings together more than twenty faculty members and students working across mechanics, control, sensing, and AI.
实验室由李敏教授领衔,现有师生二十余人,研究覆盖机械、控制、传感与人工智能等领域。
Interested in joining or collaborating?欢迎加入或开展合作
We welcome prospective students and partners in research and industry.欢迎有志于智能机器人研究的同学,以及科研与产业合作伙伴联系我们。