Research研究
IMCRL studies intelligent robots and advanced mechatronic systems, with work in embodied human–robot interaction, dexterous manipulation, intelligent electromagnetic sensing, magnetic tactile perception, and wearable exoskeletons.
实验室面向智能机器人与先进机电系统,围绕具身智能人机交互、灵巧操作、智能电磁感知、磁触觉和可穿戴外骨骼等方向开展研究。
Directions研究方向
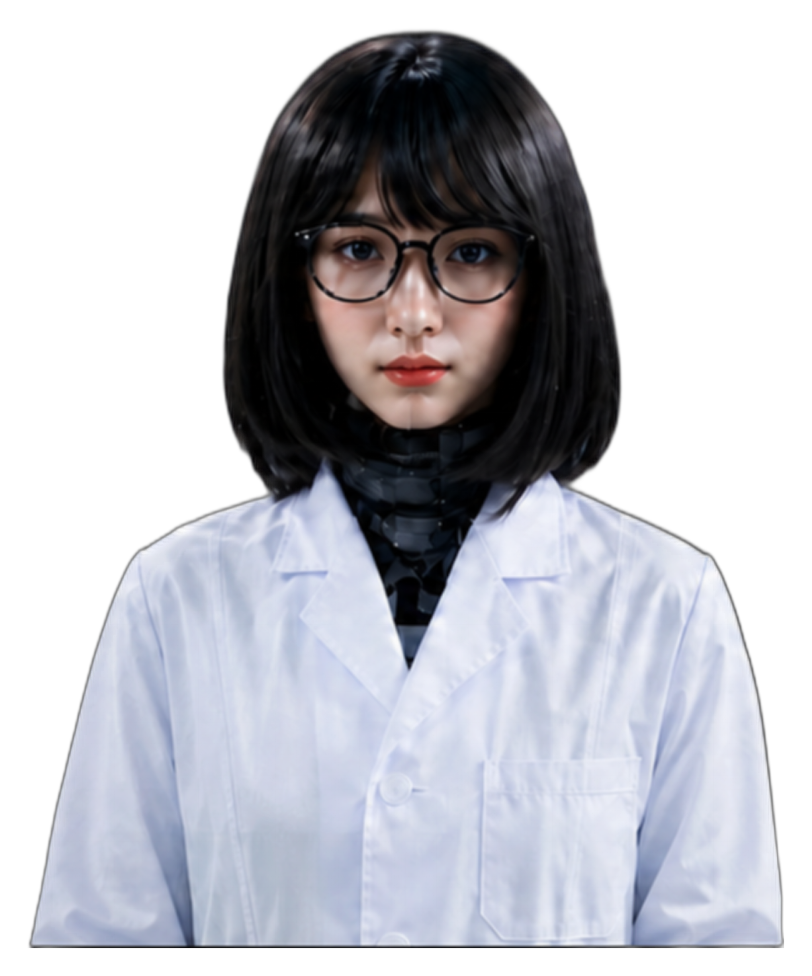
An integrated perception–cognition–generation–execution framework for natural, affective human–robot communication. 构建覆盖感知、认知、生成与执行的一体化交互框架,实现自然、富有情感的人机交流。
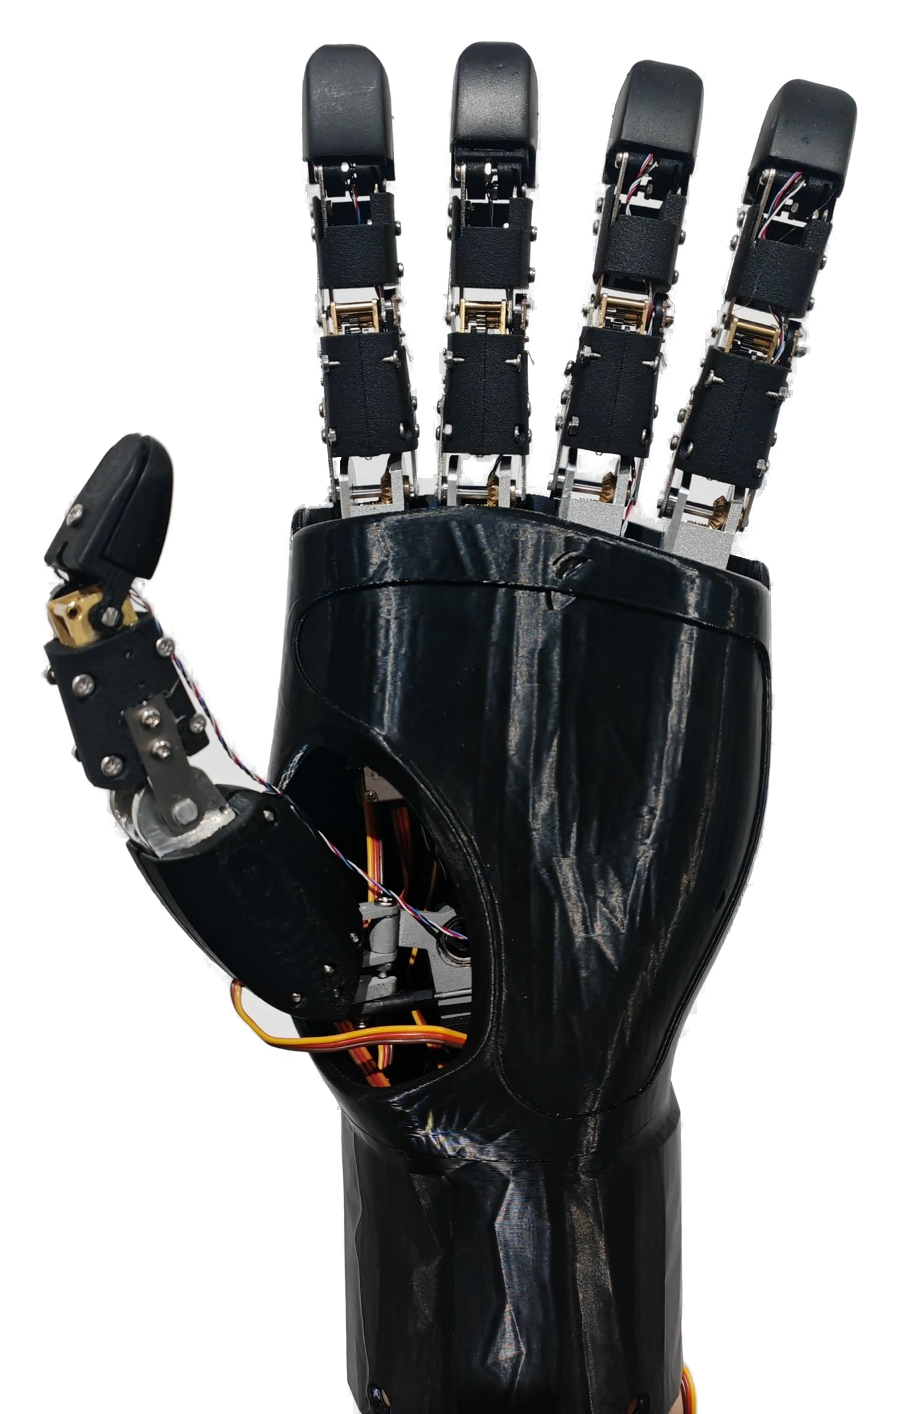
Dexterous hands, multimodal sensing, and visuo-tactile models for fine grasping and contact-rich tasks. 推进灵巧手、多模态感知与力触融合模型,服务精细抓取与富接触作业。
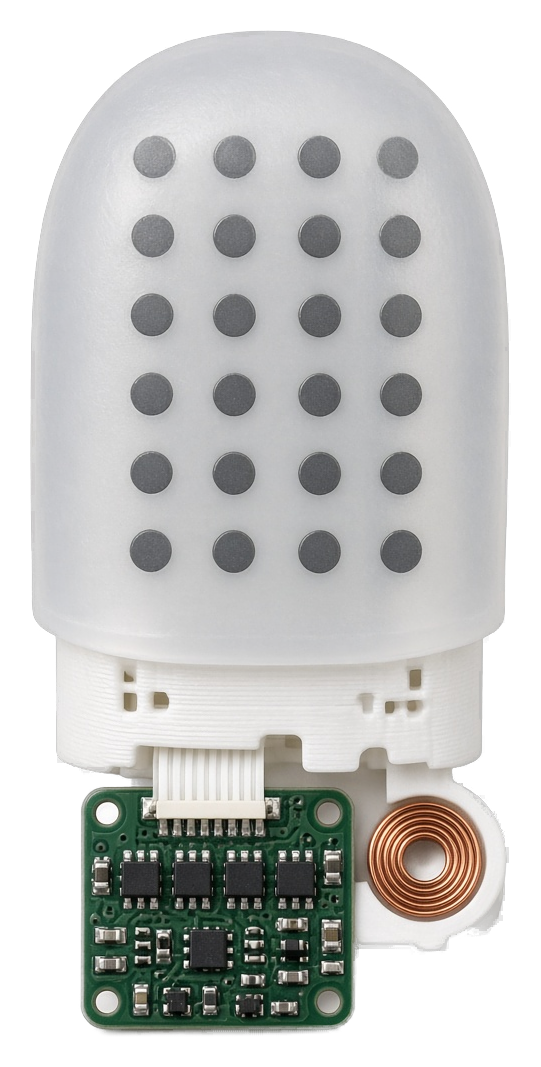
Electromagnetic inspection and arrayed magnetic tactile sensing for contact force and industrial measurement. 面向检测、传感与阵列化多维力感知。
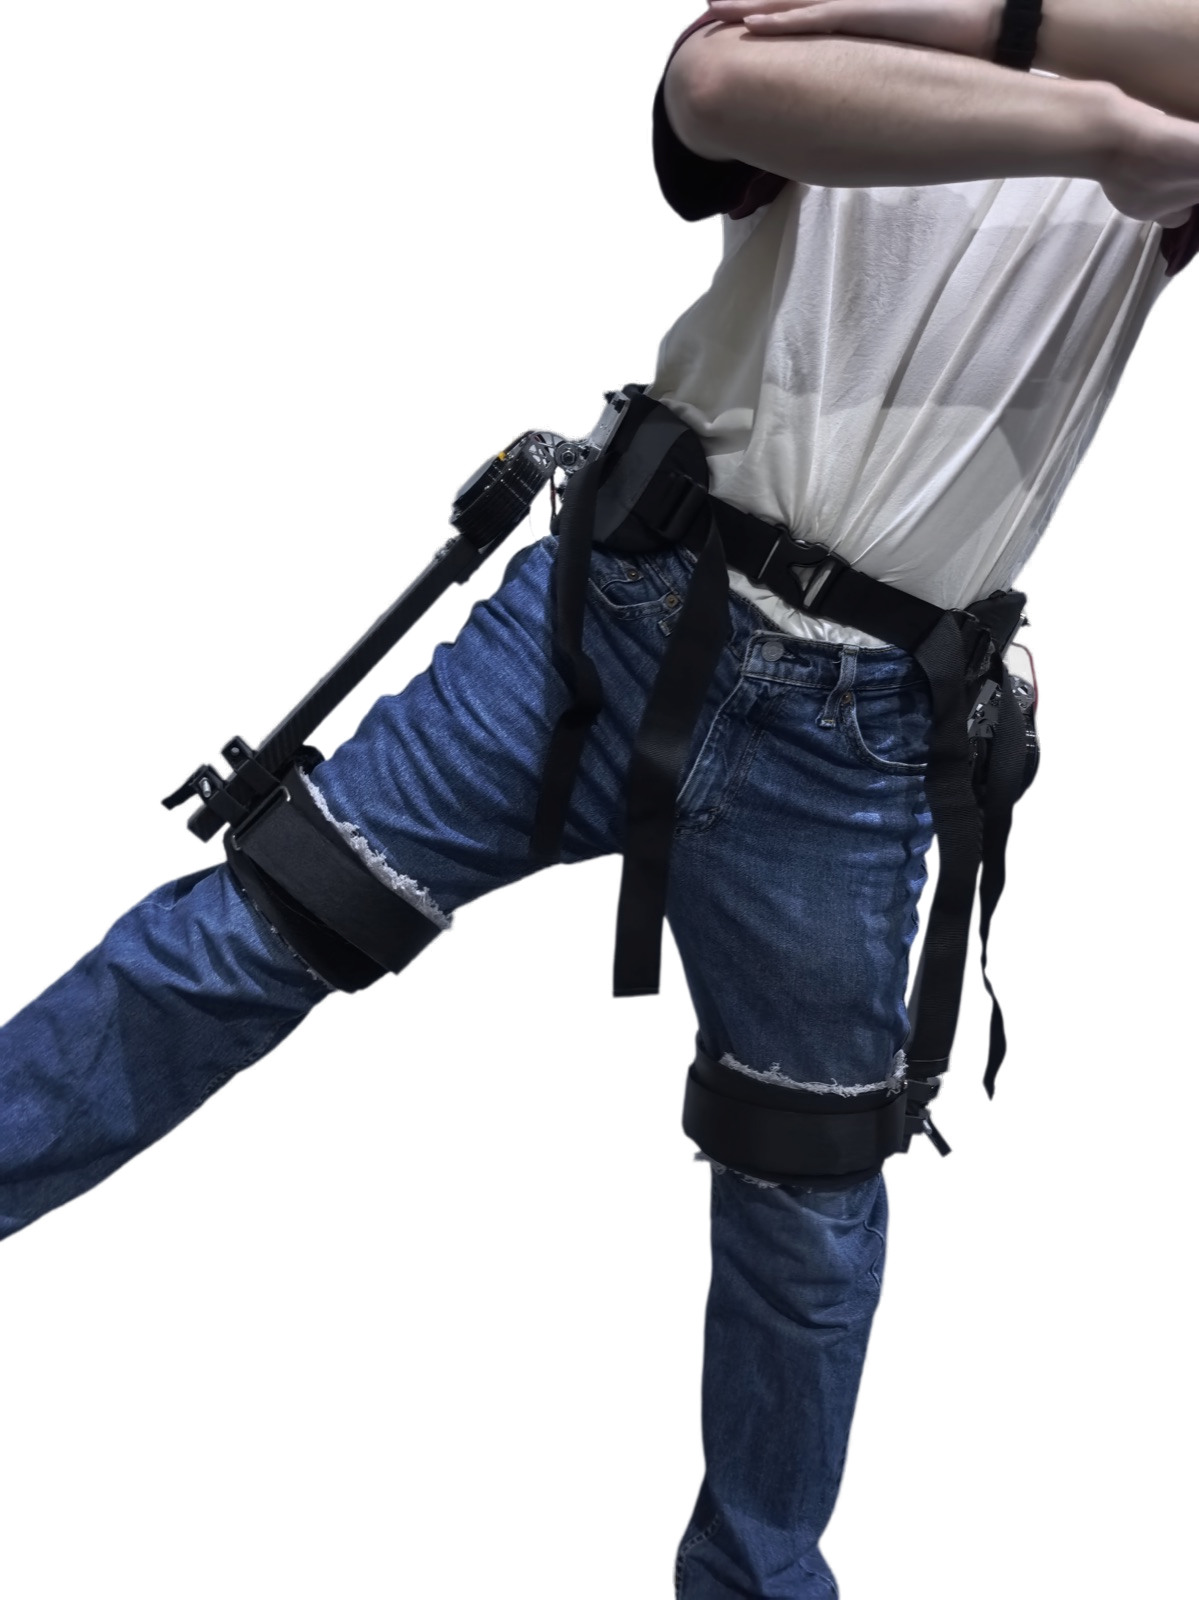
Lower-limb rehabilitation and walking assistance with lightweight, personalized exoskeleton systems. 围绕下肢人机共融康复与助行,形成轻量化、个性化助力方案。