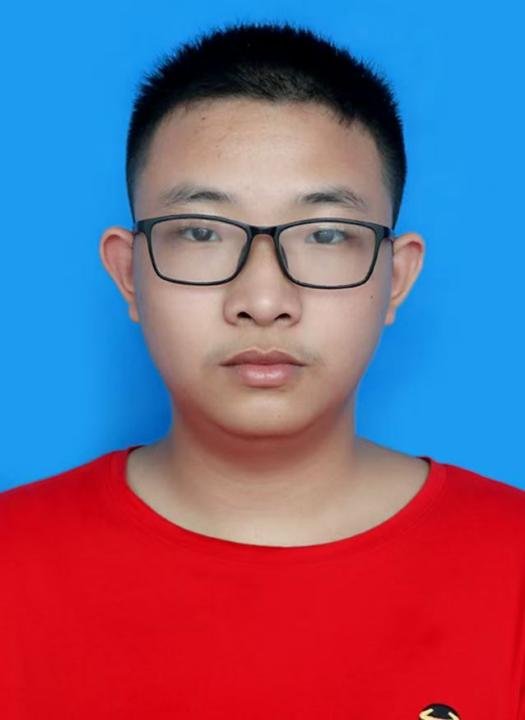
Lingbo Liu is a second-year Master Student in the School of Mechanical Science and Engineering at Huazhong University of Science and Technology. The research covers dexterous manipulation and multimodal perception, with a focus on force–tactile representation learning for hand–object interaction, and on building manipulation datasets and task policies. The aim is to give robots a more intuitive ability to complete physical manipulation tasks on their own.
刘凌波,华中科技大学机械科学与工程学院二年级硕士。主要研究机器人灵巧操作与多模态感知,专注力觉 - 触觉融合的手物交互表征学习,构建机器人操作数据集与任务策略。研究旨在赋予机器人类直觉的操作能力,具备自主完成物理操作任务的能力。